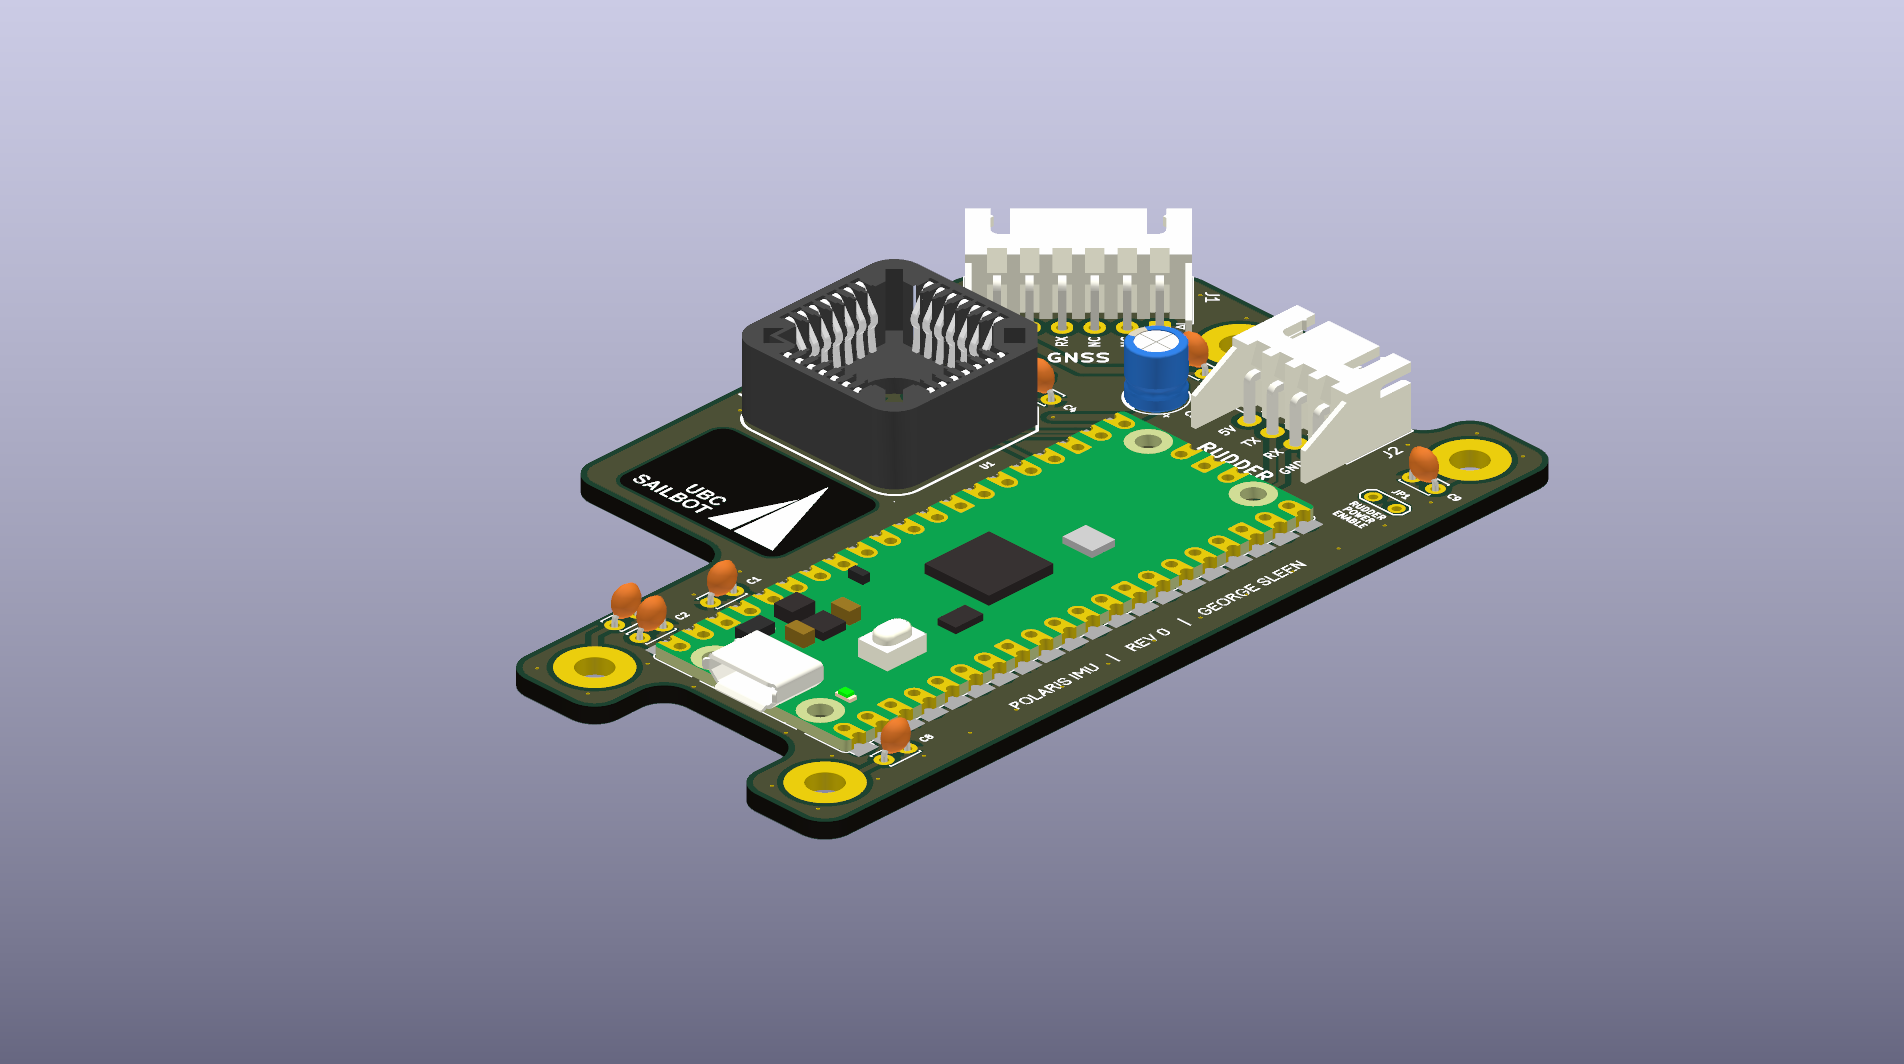
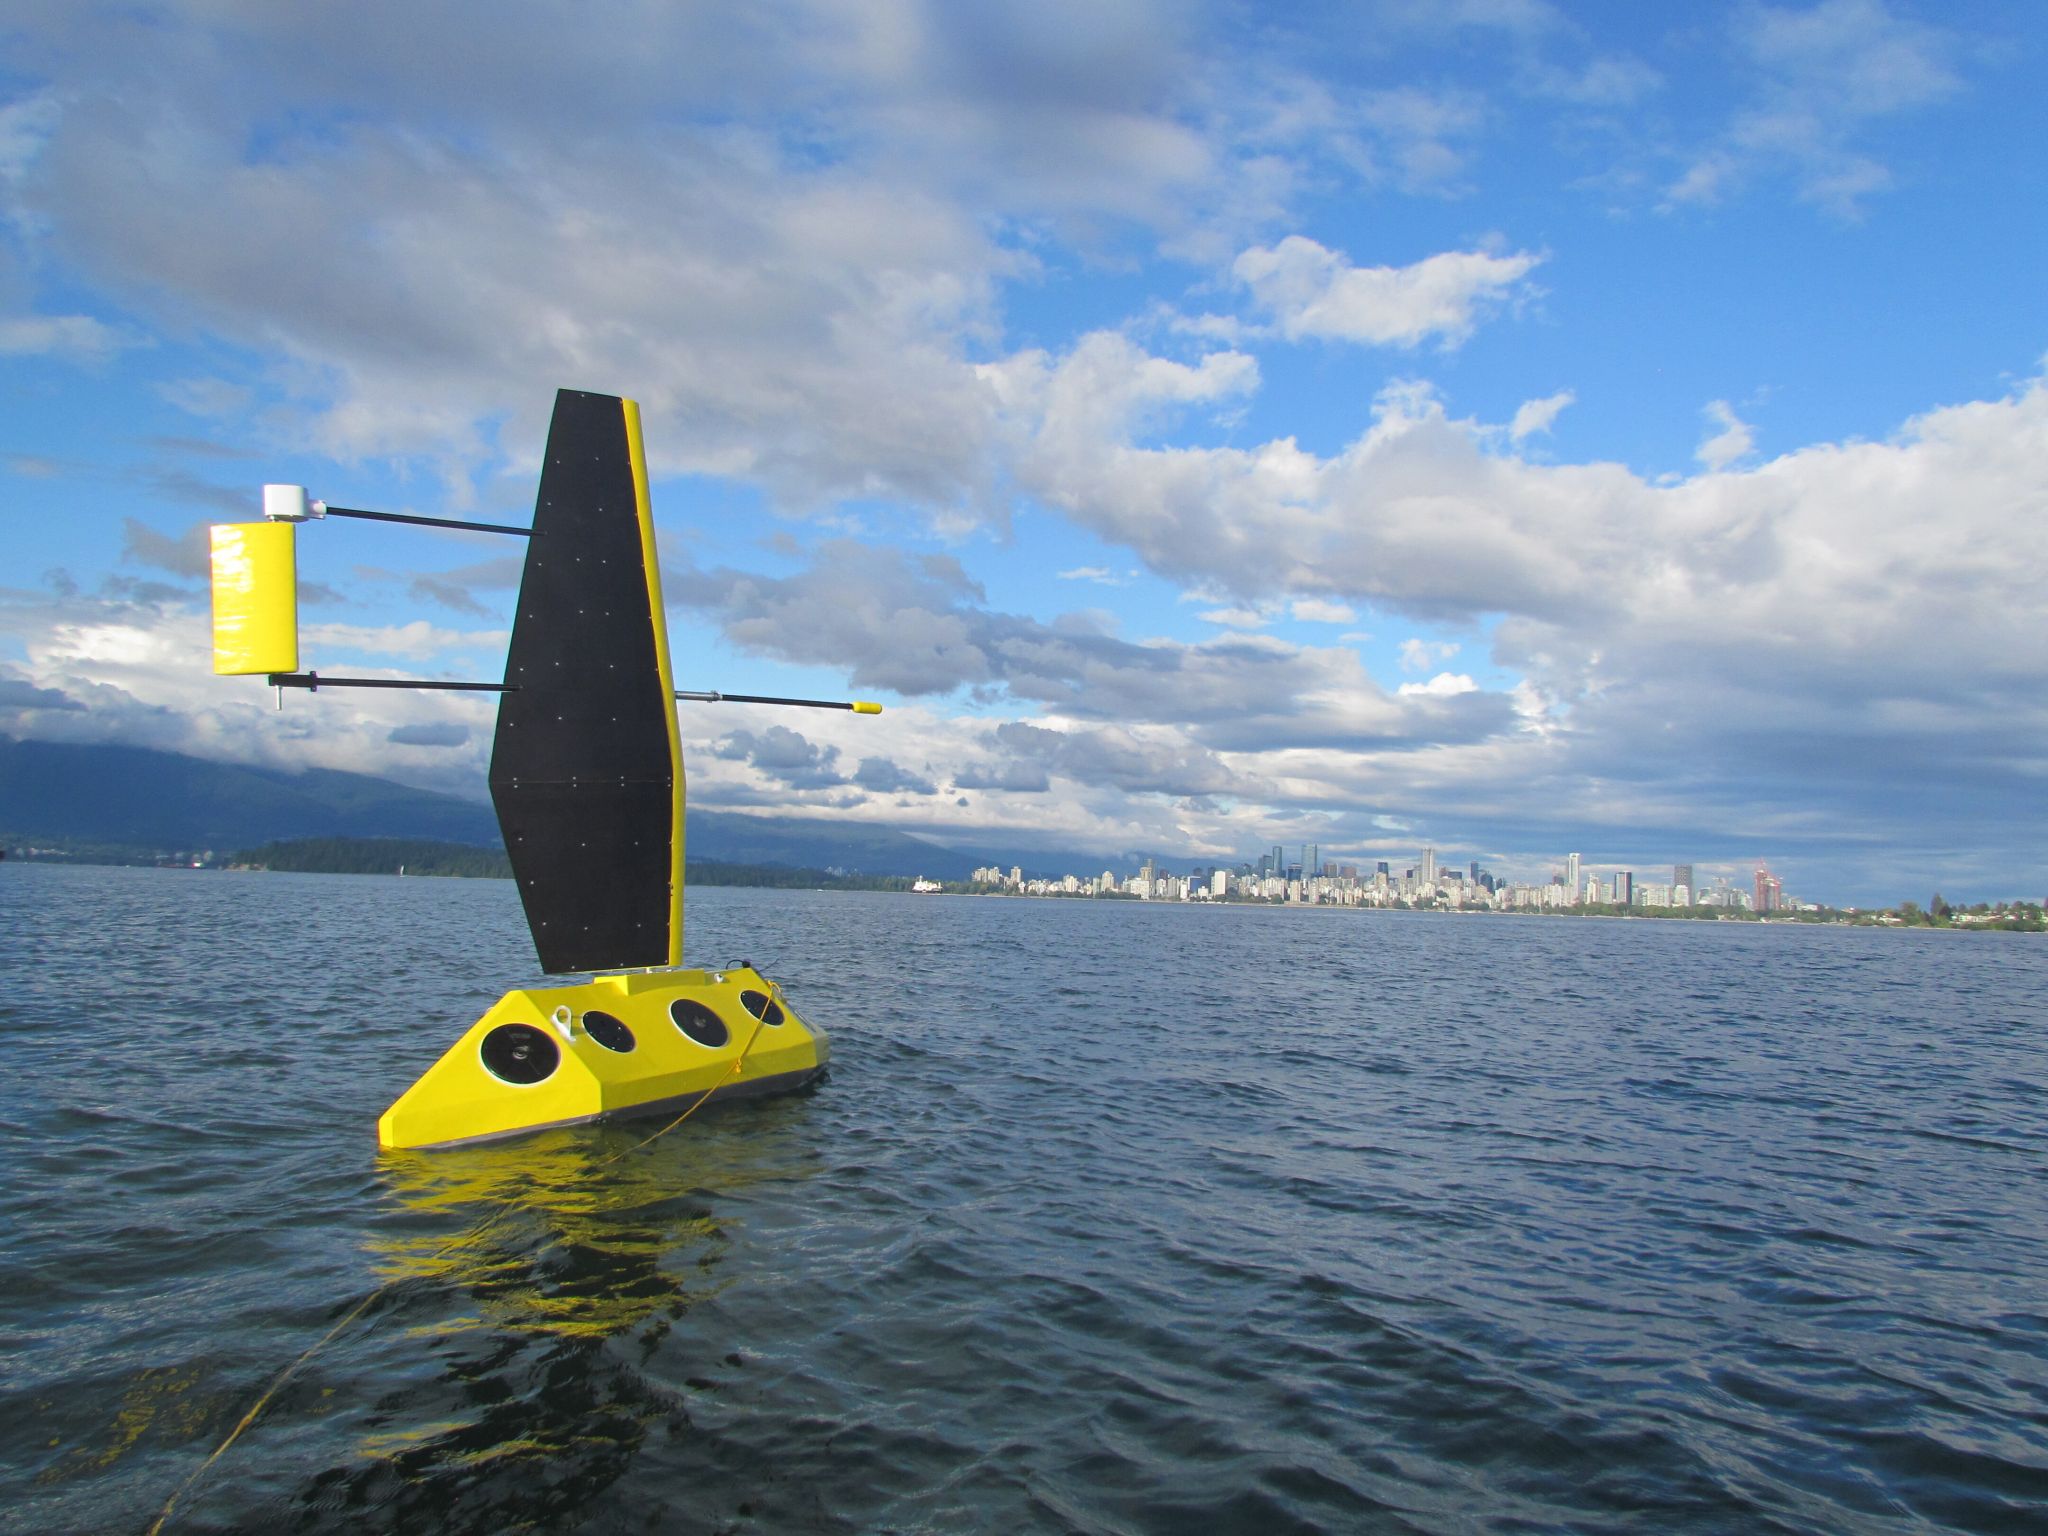
UBC Sailbot's IMU solution. Sensor fusion on a 9-axis MEMS IMU and dual antenna GNSS kit.
Autonomous robot built for UBC Engineering Physics' 2025 Pet Rescue competition.
The SuperVisor: smart glasses that turn what a camera sees into haptic feedback, with a custom neural network chip.
Fine-tuning a chat model on my cohort's Discord server and wiring it up as a bot.
Our ENPH 353 competition robot: imitation learning for driving, YOLO for reading the clue boards.
A pair of small RP2040 IR boards with an LED matrix, touch pads, USB-C, and LiPo charging.
Control circuit for a servo with speed feedback and PI control.
An 8-bit computer made of 7400-series logic, running programs in simulation.
Non-destructive Wi-Fi-controlled dorm room light switch using ESP8266 and custom mount.
The Nix flake that sets up my laptop, server, Raspberry Pi, and two OpenWrt devices.
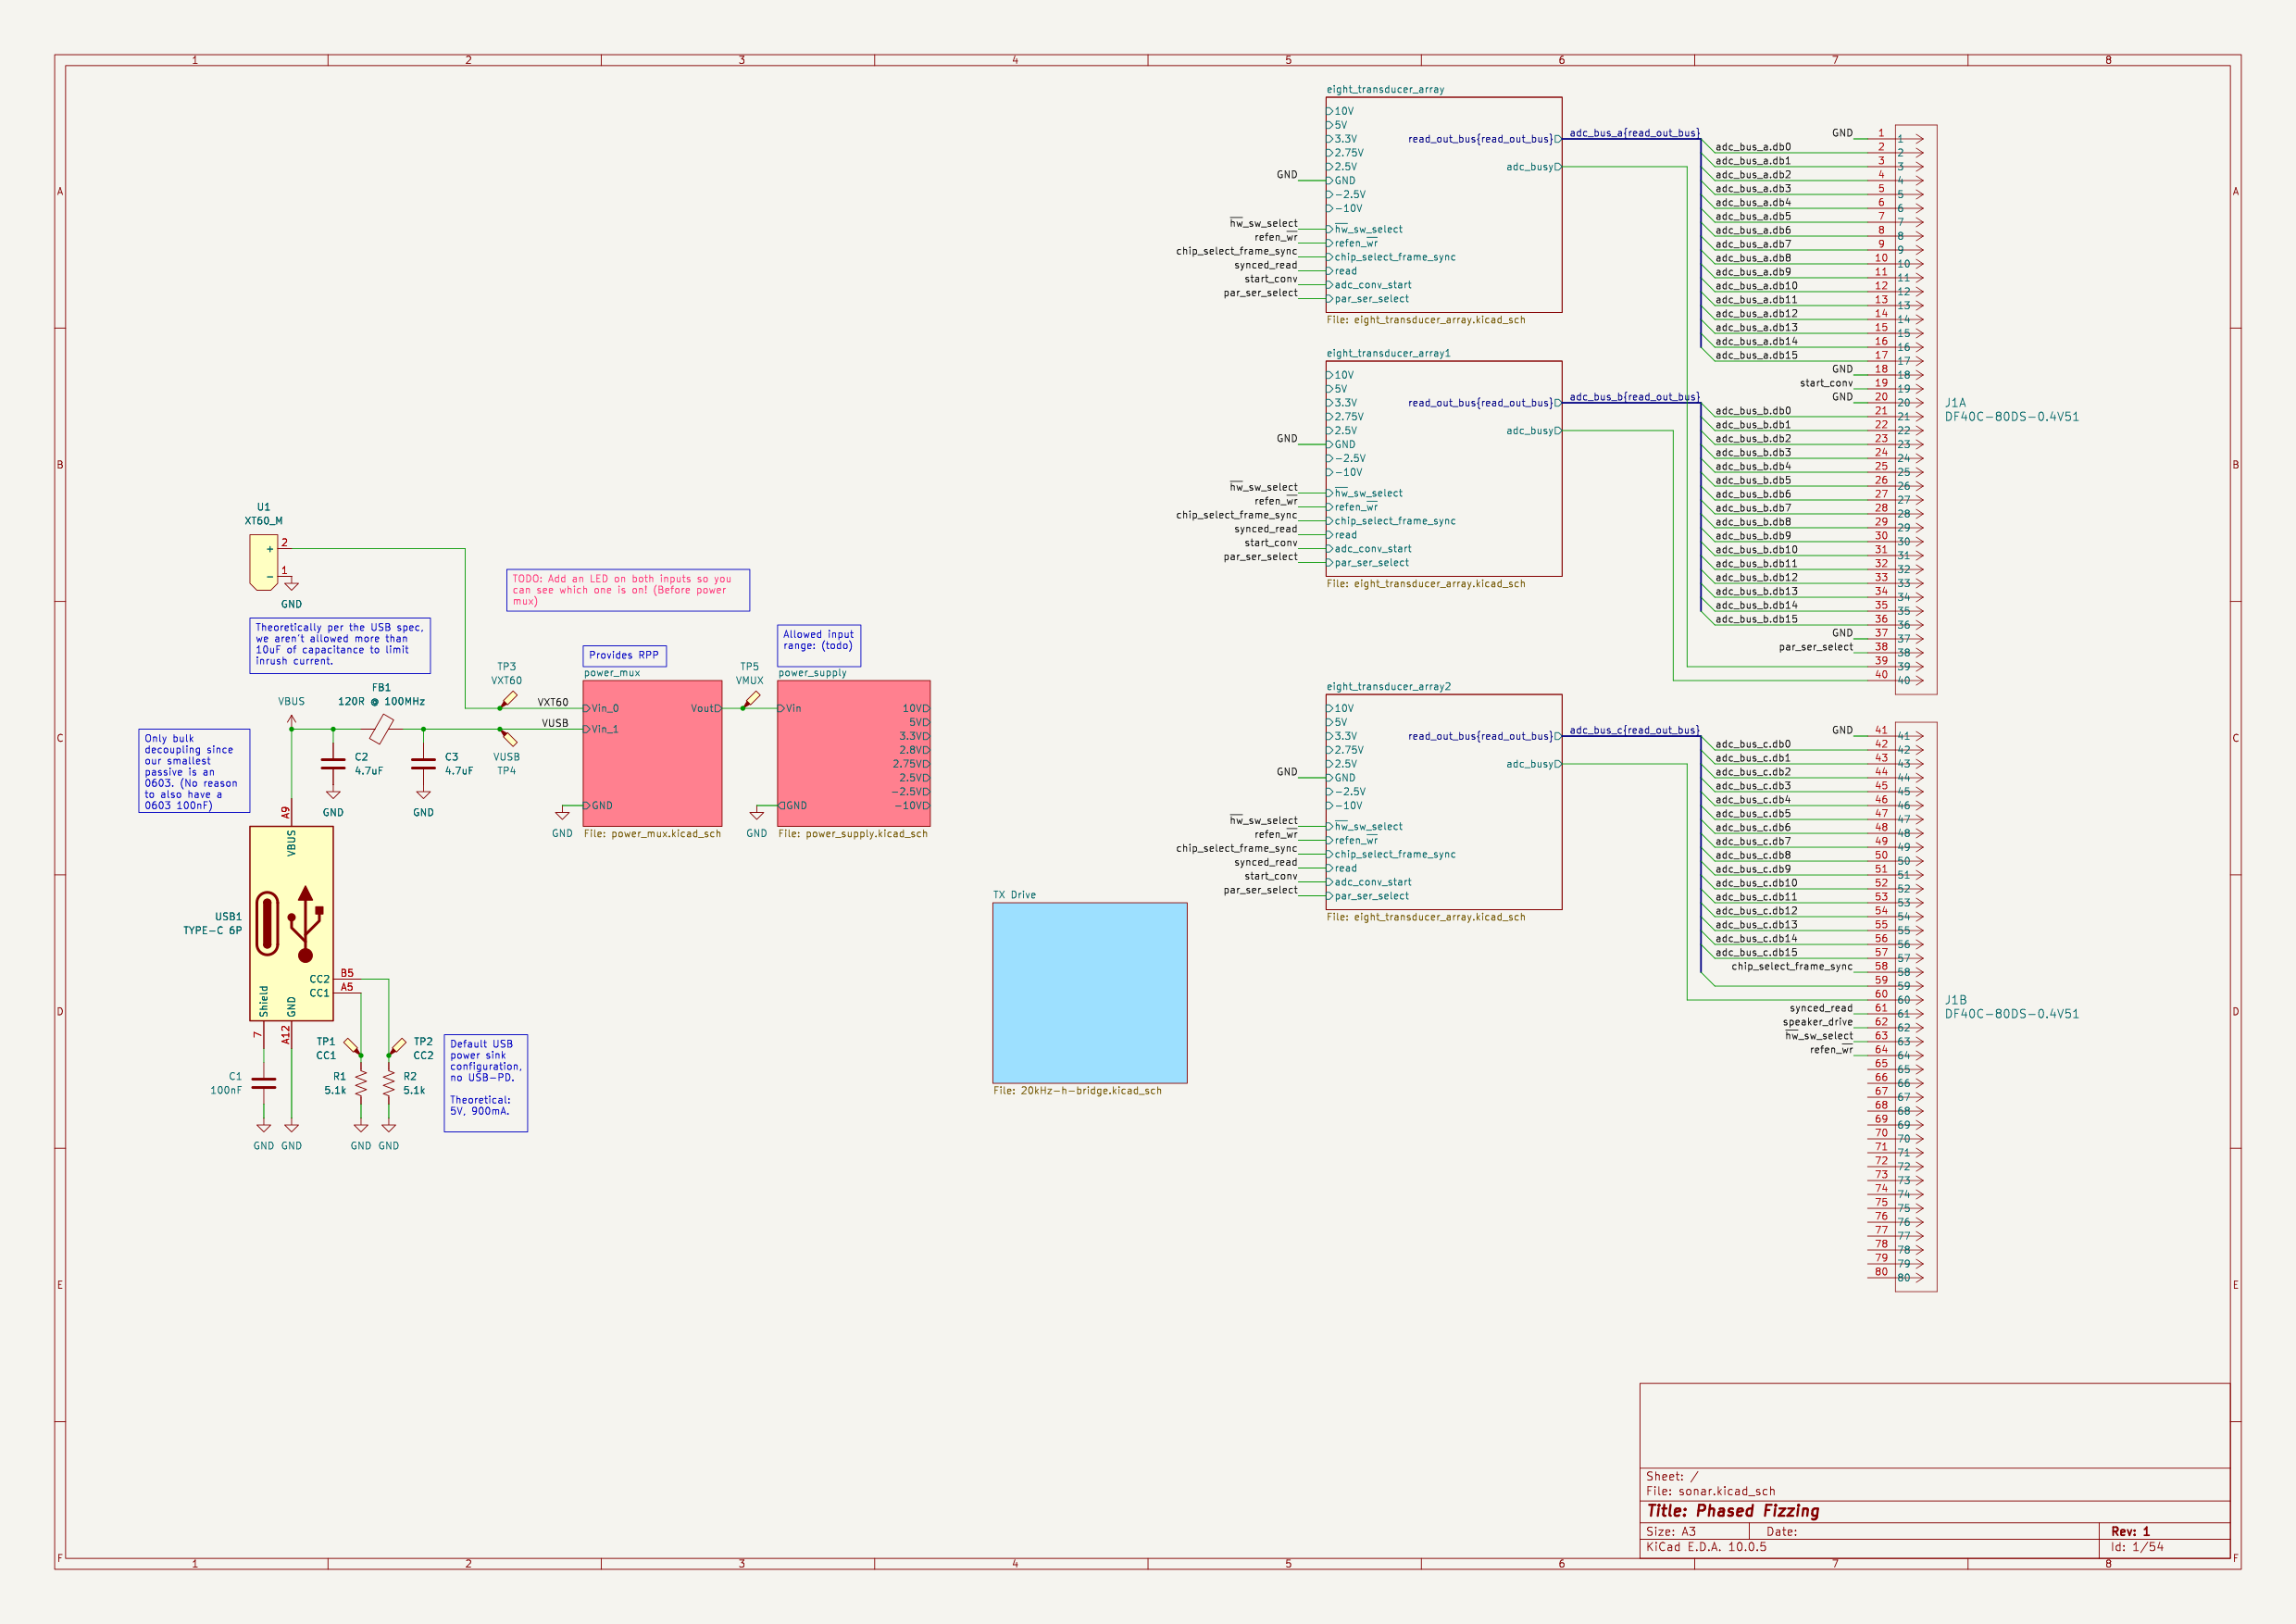
A microphone array sonar that Josh Himmens and I are designing.
A three-phase brushless motor driver on a breadboard, with firmware in Rust for the RP2040.
Firmware for the microcontrollers on UBC Sailbot's autonomous sailboat, Polaris.
Drivetrain and propeller work on UBC's human-powered submarine, then leading the team.
Backyard foundry to melt down aluminum cans.
Visualizing ionizing radiation at home.